Crew · the people layer of the open robot suite
Find the people who have built it.
Builders, labs and certified assembly teams, per robot. Nobody writes their own profile here. A profile is what a reviewed build report leaves behind, and it is judged on one thing: matches that end in a finished build.
0
Verified builders
41
Labs & makers listed
58 / 72
Robots open to crew
277
Open bounties · unfunded
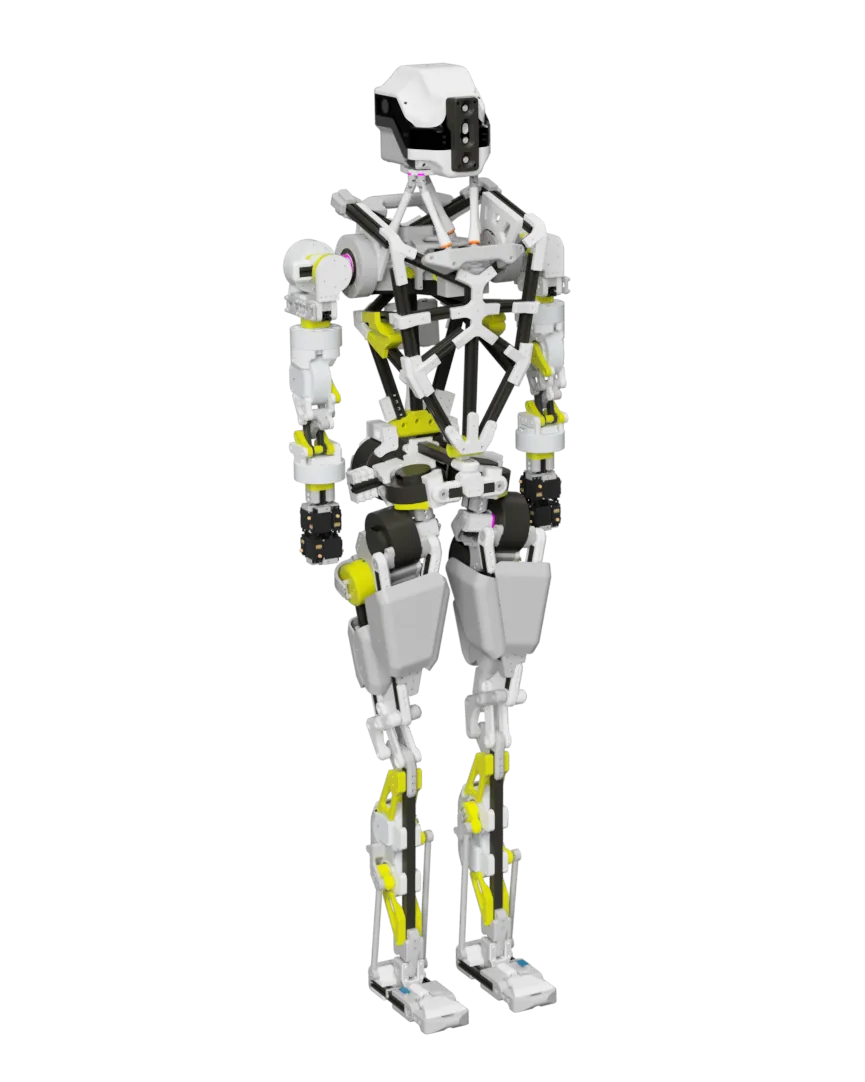
Hyperspawn · Hyperspawn
Flagship open platform · Hyperspawn's own robot · featured, not ranked
Crew up on Dropbear.
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
- Maintainer
- Hyperspawn Robotics
- Crew
- live
- Level
- L2 Sim-verified
- Verified builders
- 0
- Labs & makers
- 0
- Open bounties
- 8
- Build steps
- 40
No reviewed build yet. The first verified Dropbear builder takes the first slot on this roster.
Build it on humanoidrobot.build · train it on humanoidrobots.training
01 / How crew works
One build report, four things happen.
There is no sign-up form for builders. You build a robot, you report it with photos and bring-up logs, a person reviews it, and the profile appears. Everything after that is earned the same way.
STEP 1 report
Build report
Photos, bring-up logs and the package version you built from, filed on humanoidrobot.build.
GATE · human review of evidenceSTEP 2 profile
Profile
A reviewed report becomes a verified point on the map and a builder profile here, listing what you built and where.
GATE · verified = true on the recordSTEP 3 match
Matches
People who need help with the same robot near you get matched to you. A match counts only when it ends in a finished build.
GATE · the helped build is itself reportedSTEP 4 jobs
Certified jobs
Teams with repeat verified builds on an L5 robot can be certified by its maintainer and take paid assembly jobs.
GATE · maintainer sign-off02 / Builders
Verified builders
Only builders backed by a reviewed build report are listed. Unreviewed reports are counted, never shown.
No verified builders yet. The first one gets the first profile.
Every slot below is open. Build one of these robots, file the report, and once it is reviewed your profile is the first entry on this roster for that robot.
+15 more buildable robots with an open first slot. Crew ledger
03 / Maintainers
Maintainers
The organisation that publishes a robot is its maintainer. Only a maintainer can sign a package to L5, and only an L5 package can have certified teams. A vacant seat means the maker is gone and the robot needs adopting.
/1x
AgiBot (Zhiyuan Robotics)
ChinaAgility Robotics
United StatesAlexander Koch / Hugging Face LeRobot
seat vacantAnnin Robotics
United StatesApptronik
United StatesBooster Robotics
ChinaBoston Dynamics
United StatesCarnegie Mellon University
United StatesChestnut Robotics (formerly TetherIA)
United StatesDuke University General Robotics Lab
United StatesEngineAI (Zhongqing Robotics)
ChinaEngineered Arts
United KingdomFigure AI
United StatesFourier (Fourier Intelligence)
ChinaGael Langevin
FranceGalbot (Galaxy General Robot)
ChinaHumanoid (SKL Robotics Ltd)
United KingdomHyperspawn Robotics
IndiaJames Bruton (XRobots)
seat vacantK-Scale Labs
United StatesKepler Robotics (Shanghai Kepler Exploration Robot Co.)
ChinaLeju Robotics
ChinaMenlo Research (Asimov)
SingaporeMentee Robotics
IsraelNASA Jet Propulsion Laboratory
United StatesNEURA Robotics
GermanyNoetix Robotics (Songyan Dynamics)
ChinaOpen Dynamic Robot Initiative
GermanyPAL Robotics
SpainPetoi
United StatesPNDbotics
ChinaPollen Robotics
FrancePoppy Project (Inria Flowers)
seat vacantPudu Robotics
ChinaRainbow Robotics
South KoreaRoboParty (Shanghai RoboParty Technology)
ChinaROBOTIS
South KoreaRoger Cheng
United StatesSanctuary AI
CanadaSIGRobotics UIUC / Hugging Face LeRobot
United StatesSource Robotics
CroatiaStanford (Tony Zhao et al.)
United States- ALOHA · L2
- Stanford Pupper (v1) · L1
- Pupper v3 · L1
- ToddlerBot · L2
- UMI Gripper (Universal Manipulation Interface) · L2
Tesla
United StatesThe Robot Studio / Hugging Face
FranceThe Robot Studio & Hugging Face
FranceUBTech Robotics
ChinaUC Berkeley Hybrid Robotics Lab
United StatesUnitree Robotics
ChinaXPeng
China4 robots orphaned: Koch v1.1 Low-Cost Robot Arm, Z-Bot (Zeroth Bot), Poppy Humanoid, openDog V3. They stay buildable; they cannot be certified until adopted.
04 / Labs
Labs, makers and spaces
Places that work on a listed robot, from public sources. A lab is not a builder profile: it becomes one when it files a build report. Research labs directory (13) →
05 / Per robot
Crew ledger
Every robot in the registry, with its crew state. Closed robots have no builders by definition: the hardware is not open.
| Robot | Crew | Level | Maintainer | Builders | Labs | Bounties |
|---|---|---|---|---|---|---|
4NE1 neura/4ne1 | partial | L0 Indexed | NEURA Robotics | 0 | 1 | 1 |
 Adam Lite pndbotics/adam-lite | partial | L2 Sim-verified | PNDbotics | 0 | 1 | 1 |
 Aero Hand Open chestnut/aero-hand-open | live | L2 Sim-verified | Chestnut Robotics (formerly TetherIA) | 0 | 0 | 8 |
AgiBot A2 (Yuanzheng) agibot/a2 | partial | L0 Indexed | AgiBot (Zhiyuan Robotics) | 0 | 1 | 1 |
AgiBot Lingxi X1 agibot/x1 | live | L1 Compiled | AgiBot (Zhiyuan Robotics) | 0 | 1 | 8 |
 ALOHA stanford/aloha | live | L2 Sim-verified | Stanford (Tony Zhao et al.) | 0 | 1 | 8 |
 AmazingHand pollen/amazing-hand | live | L1 Compiled | Pollen Robotics | 0 | 1 | 8 |
 Ameca engineeredarts/ameca | partial | L0 Indexed | Engineered Arts | 0 | 1 | 2 |
 Apollo apptronik/apollo | closed | L2 Sim-verified | Apptronik | 0 | 1 | 1 |
 AR4 anninrobotics/ar4 | live | L1 Compiled | Annin Robotics | 0 | 0 | 8 |
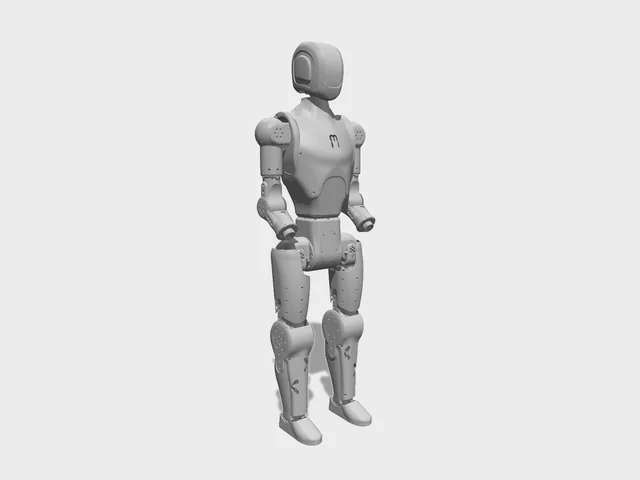 Asimov 1 menlo/asimov | live | L1 Compiled | Menlo Research (Asimov) | 0 | 1 | 8 |
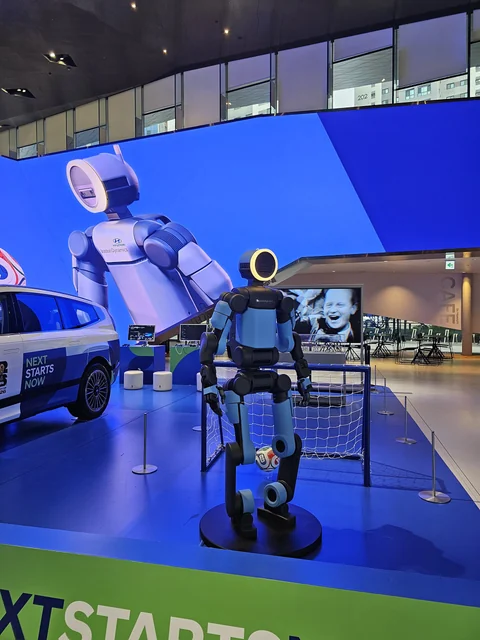 Atlas (electric) bostondynamics/atlas | closed | L0 Indexed | Boston Dynamics | 0 | 1 | 1 |
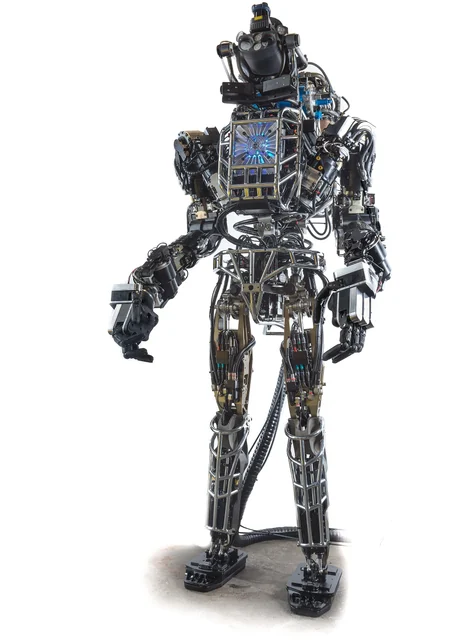 Atlas (hydraulic) bostondynamics/atlas-hydraulic | closed | L0 Indexed | Boston Dynamics | 0 | 1 | 1 |
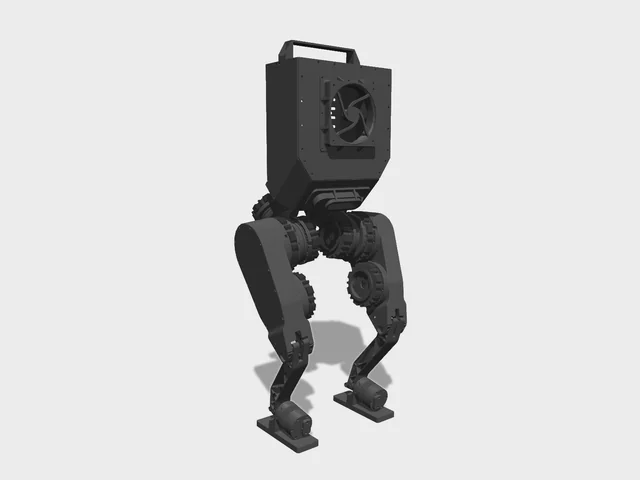 Berkeley Humanoid berkeley/humanoid | closed | L2 Sim-verified | UC Berkeley Hybrid Robotics Lab | 0 | 1 | 1 |
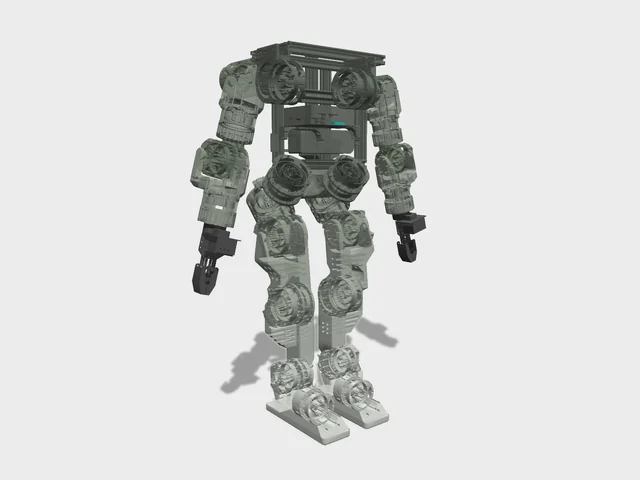 Berkeley Humanoid Lite berkeley/humanoid-lite | live | L2 Sim-verified | UC Berkeley Hybrid Robotics Lab | 0 | 1 | 7 |
Bittle / Bittle X petoi/bittle | partial | L1 Compiled | Petoi | 0 | 1 | 1 |
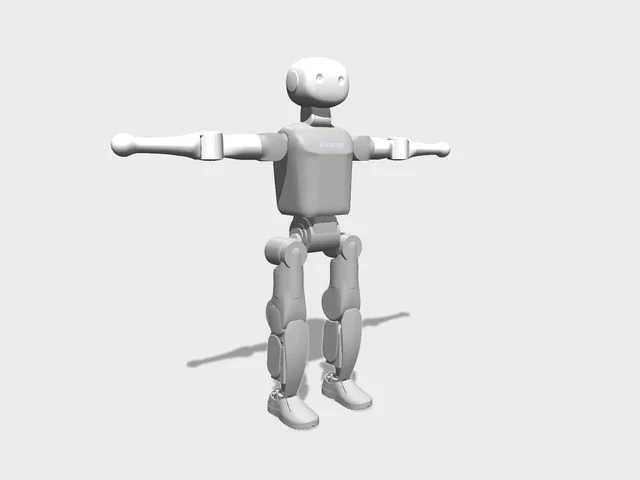 Booster K1 booster/k1 | partial | L1 Compiled | Booster Robotics | 0 | 1 | 1 |
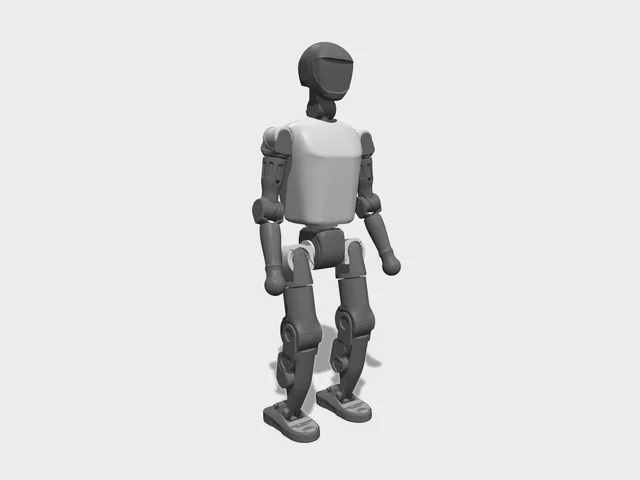 Booster T1 booster/t1 | partial | L2 Sim-verified | Booster Robotics | 0 | 1 | 1 |
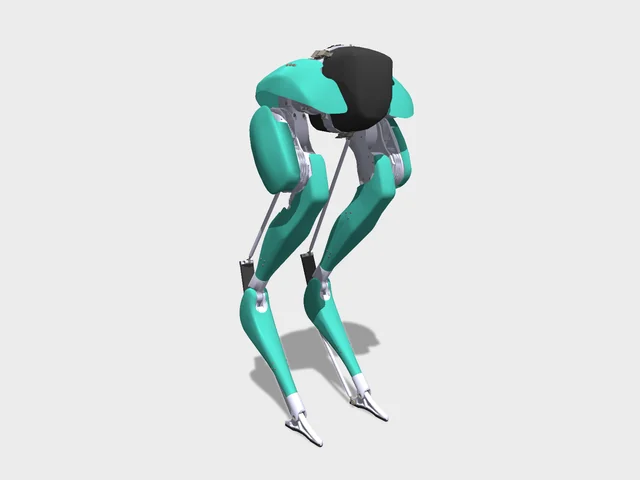 Cassie agility/cassie | closed | L2 Sim-verified | Agility Robotics | 0 | 1 | 1 |
Digit agility/digit | closed | L0 Indexed | Agility Robotics | 0 | 1 | 1 |
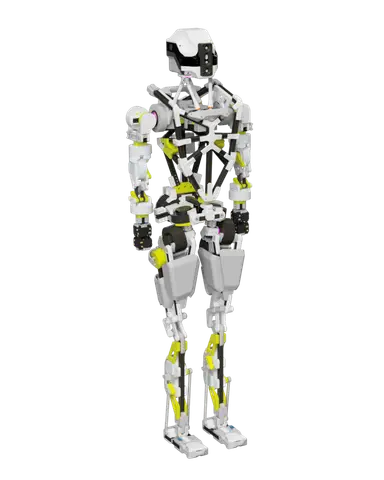 Dropbear hyperspawn/dropbear | live | L2 Sim-verified | Hyperspawn Robotics | 0 | 0 | 8 |
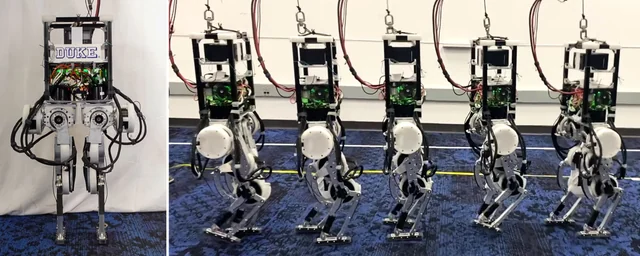 Duke Humanoid v1 duke/duke-humanoid | live | L1 Compiled | Duke University General Robotics Lab | 0 | 1 | 8 |
EngineAI PM01 engineai/pm01 | partial | L1 Compiled | EngineAI (Zhongqing Robotics) | 0 | 1 | 1 |
Figure 02 figure/02 | closed | L0 Indexed | Figure AI | 0 | 1 | 1 |
Figure 03 figure/03 | closed | L0 Indexed | Figure AI | 0 | 1 | 1 |
 Fourier GR-1 fourier/gr1 | partial | L1 Compiled | Fourier (Fourier Intelligence) | 0 | 1 | 1 |
 Fourier GR-2 fourier/gr2 | partial | L1 Compiled | Fourier (Fourier Intelligence) | 0 | 1 | 1 |
 Fourier N1 fourier/n1 | live | L2 Sim-verified | Fourier (Fourier Intelligence) | 0 | 1 | 6 |
 Galbot G1 galbot/g1 | partial | L0 Indexed | Galbot (Galaxy General Robot) | 0 | 1 | 1 |
HMND 01 humanoid/hmnd-01 | closed | L0 Indexed | Humanoid (SKL Robotics Ltd) | 0 | 1 | 1 |
 HopeJR huggingface/hopejr | live | L1 Compiled | The Robot Studio & Hugging Face | 0 | 0 | 8 |
 InMoov inmoov/inmoov | live | L1 Compiled | Gael Langevin | 0 | 0 | 9 |
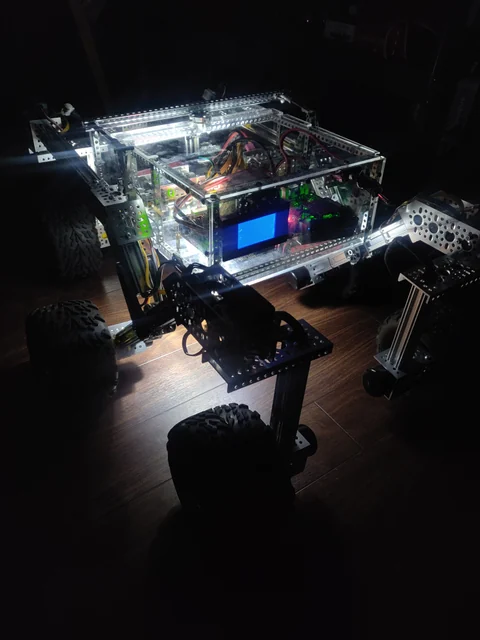 JPL Open Source Rover jpl/open-source-rover | live | L1 Compiled | NASA Jet Propulsion Laboratory | 0 | 1 | 7 |
 K-Bot kscale/kbot | partial | L1 Compiled | K-Scale Labs | 0 | 1 | 8 |
Kangaroo pal/kangaroo | partial | L1 Compiled | PAL Robotics | 0 | 1 | 1 |
Kepler Forerunner K2 "Bumblebee" kepler/k2 | partial | L0 Indexed | Kepler Robotics (Shanghai Kepler Exploration Robot Co.) | 0 | 1 | 1 |
 Koch v1.1 Low-Cost Robot Arm alexanderkoch/koch-v1-1 | partial | L2 Sim-verified | vacant | 0 | 0 | 9 |
 LEAP Hand cmu/leap-hand | live | L2 Sim-verified | Carnegie Mellon University | 0 | 1 | 7 |
Leju Kuavo leju/kuavo | partial | L1 Compiled | Leju Robotics | 0 | 1 | 1 |
 LeKiwi uiuc/lekiwi | live | L1 Compiled | SIGRobotics UIUC / Hugging Face LeRobot | 0 | 1 | 4 |
MenteeBot mentee/menteebot | closed | L0 Indexed | Mentee Robotics | 0 | 1 | 1 |
NEO 1x/neo | partial | L0 Indexed | 1X Technologies | 0 | 1 | 2 |
Noetix Bumi noetix/bumi | partial | L0 Indexed | Noetix Robotics (Songyan Dynamics) | 0 | 1 | 1 |
Noetix N2 noetix/n2 | partial | L0 Indexed | Noetix Robotics (Songyan Dynamics) | 0 | 1 | 1 |
openDog V3 xrobots/opendog | partial | L1 Compiled | vacant | 0 | 0 | 10 |
 OpenMANIPULATOR-X (RM-X52-TNM) robotis/openmanipulator-x | partial | L1 Compiled | ROBOTIS | 0 | 1 | 1 |
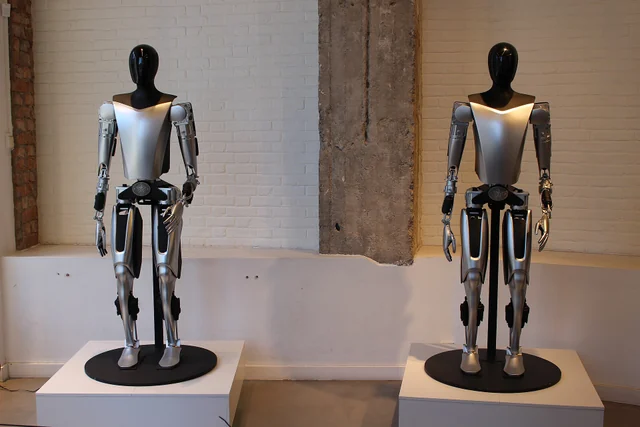 Optimus tesla/optimus | closed | L0 Indexed | Tesla | 0 | 1 | 1 |
 PAROL6 sourcerobotics/parol6 | live | L1 Compiled | Source Robotics | 0 | 1 | 8 |
Phoenix sanctuary/phoenix | closed | L0 Indexed | Sanctuary AI | 0 | 1 | 1 |
 Poppy Humanoid poppy/poppy-humanoid | partial | L1 Compiled | vacant | 0 | 1 | 9 |
PUDU D9 pudu/d9 | closed | L0 Indexed | Pudu Robotics | 0 | 1 | 1 |
 Pupper v3 stanford/pupper-v3 | live | L1 Compiled | Stanford Student Robotics / Hands-On Robotics | 0 | 1 | 8 |
 Rainbow Robotics RB-Y1 rainbow/rby1 | partial | L2 Sim-verified | Rainbow Robotics | 0 | 1 | 1 |
 Reachy 2 pollen/reachy2 | partial | L1 Compiled | Pollen Robotics (Hugging Face) | 0 | 1 | 1 |
 ROBOTIS OP3 robotis/op3 | partial | L2 Sim-verified | ROBOTIS | 0 | 1 | 1 |
 ROBOTO_ORIGIN roboparty/roboto-origin | live | L1 Compiled | RoboParty (Shanghai RoboParty Technology) | 0 | 1 | 8 |
Sawppy the Rover sawppy/sawppy | live | L1 Compiled | Roger Cheng | 0 | 0 | 9 |
 SO-100 (SO-ARM100) therobotstudio/so-100 | partial | L2 Sim-verified | The Robot Studio / Hugging Face | 0 | 0 | 6 |
 SO-101 (SO-ARM101) therobotstudio/so-101 | live | L2 Sim-verified | The Robot Studio / Hugging Face | 0 | 0 | 6 |
 Solo-12 odri/solo-12 | live | L1 Compiled | Open Dynamic Robot Initiative | 0 | 1 | 8 |
Stanford Pupper (v1) stanford/pupper | partial | L1 Compiled | Stanford Student Robotics | 0 | 1 | 8 |
 TALOS pal/talos | partial | L2 Sim-verified | PAL Robotics | 0 | 1 | 1 |
 ToddlerBot stanford/toddlerbot | live | L2 Sim-verified | Stanford University | 0 | 1 | 7 |
UBTech Walker S (S1 / S2) ubtech/walker-s | partial | L0 Indexed | UBTech Robotics | 0 | 1 | 1 |
 UMI Gripper (Universal Manipulation Interface) stanford/umi-gripper | live | L2 Sim-verified | Stanford / Columbia / Toyota Research Institute | 0 | 1 | 8 |
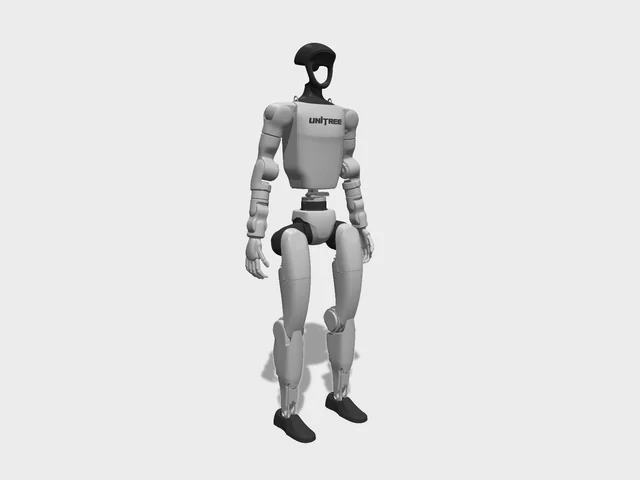 Unitree G1 unitree/g1 | partial | L2 Sim-verified | Unitree Robotics | 0 | 1 | 1 |
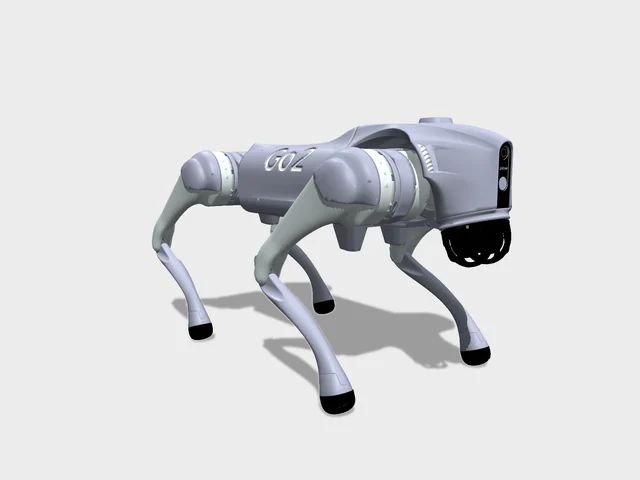 Unitree Go2 unitree/go2 | partial | L2 Sim-verified | Unitree Robotics | 0 | 1 | 1 |
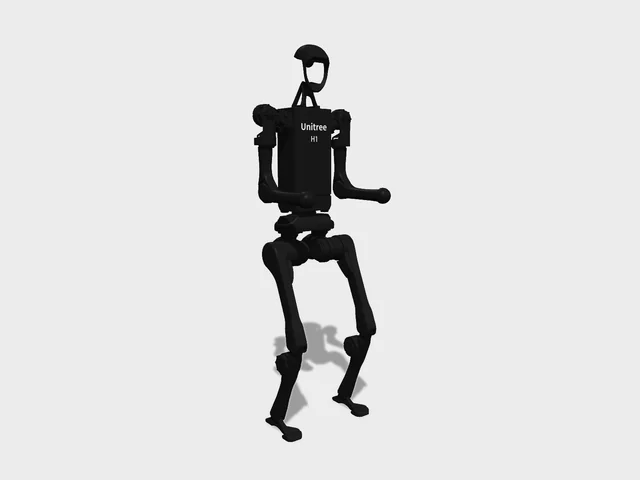 Unitree H1 unitree/h1 | partial | L2 Sim-verified | Unitree Robotics | 0 | 1 | 1 |
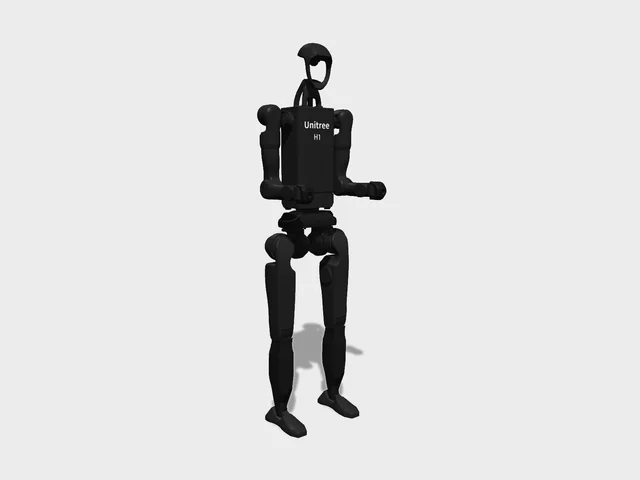 Unitree H1-2 unitree/h1-2 | partial | L1 Compiled | Unitree Robotics | 0 | 1 | 1 |
 Unitree R1 unitree/r1 | partial | L1 Compiled | Unitree Robotics | 0 | 1 | 1 |
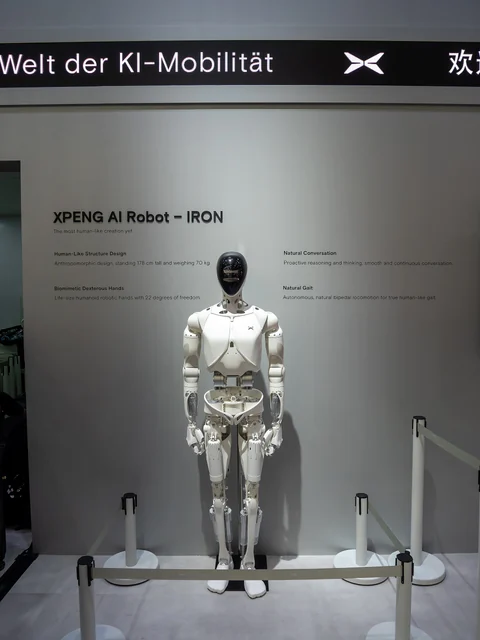 XPeng IRON xpeng/iron | closed | L0 Indexed | XPeng | 0 | 1 | 1 |
 Z-Bot (Zeroth Bot) kscale/zbot | partial | L1 Compiled | vacant | 0 | 1 | 9 |
06 / Bounties
Work nobody has claimed
Generated from gaps in the registry: missing packages, sources, offers, torque values, maintainers. When the data is filled, the bounty closes itself. No amounts are shown because none are committed; funding comes from hyperspawn.org grants.
| ID | Type | Bounty | Unlocks |
|---|---|---|---|
| HB-31B1S | Adopt | Adopt Koch v1.1 Low-Cost Robot Arm as maintainer | L5 Certified |
| HB-4OBNH | Adopt | Adopt openDog V3 as maintainer | L5 Certified |
| HB-81RLK | Adopt | Adopt Poppy Humanoid as maintainer | L5 Certified |
| HB-1GFI6 | Adopt | Adopt Z-Bot (Zeroth Bot) as maintainer | L5 Certified |
| HB-2D7CO | Sim port | Port Ameca to URDF / MJCF | L2 Sim-verified |
| HB-33N61 | Sim port | Port InMoov to URDF / MJCF | L2 Sim-verified |