Cassie
Agility Robotics · United States · Salem
crew closedL2 Sim-verifieddiscontinued
Torso-less bipedal research robot spun out of Oregon State University and sold to research labs. Superseded by Digit, which reuses its leg design.
humanoidrobots.systemsKnow it
humanoidrobot.buildBuild itclosed · Closed hardware; no public CAD or BOM.
humanoidrobots.trainingTrain ithumanoidrobots.teamFind its crewclosed · Not sold to individuals or labs.
humanoidrobots.earthSee it on the mapclosed · No public units to map.
Contact sheet · credit and license on every frame
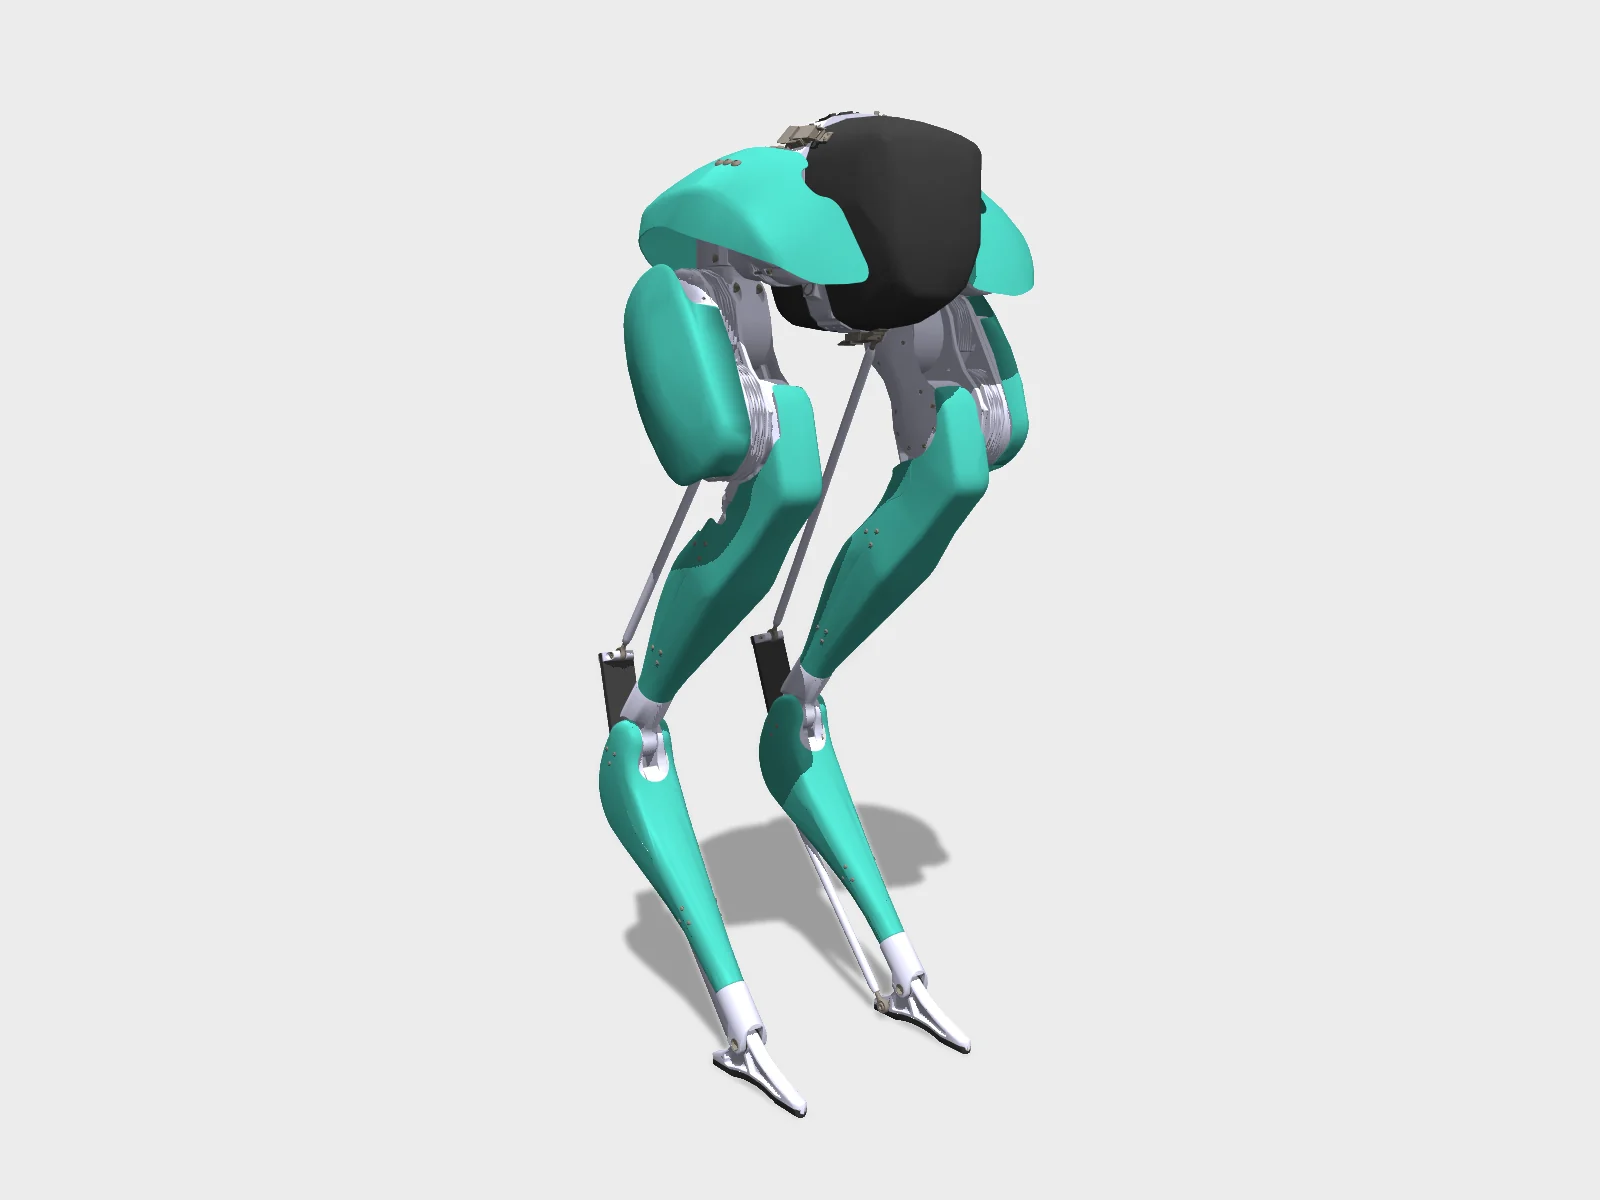
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 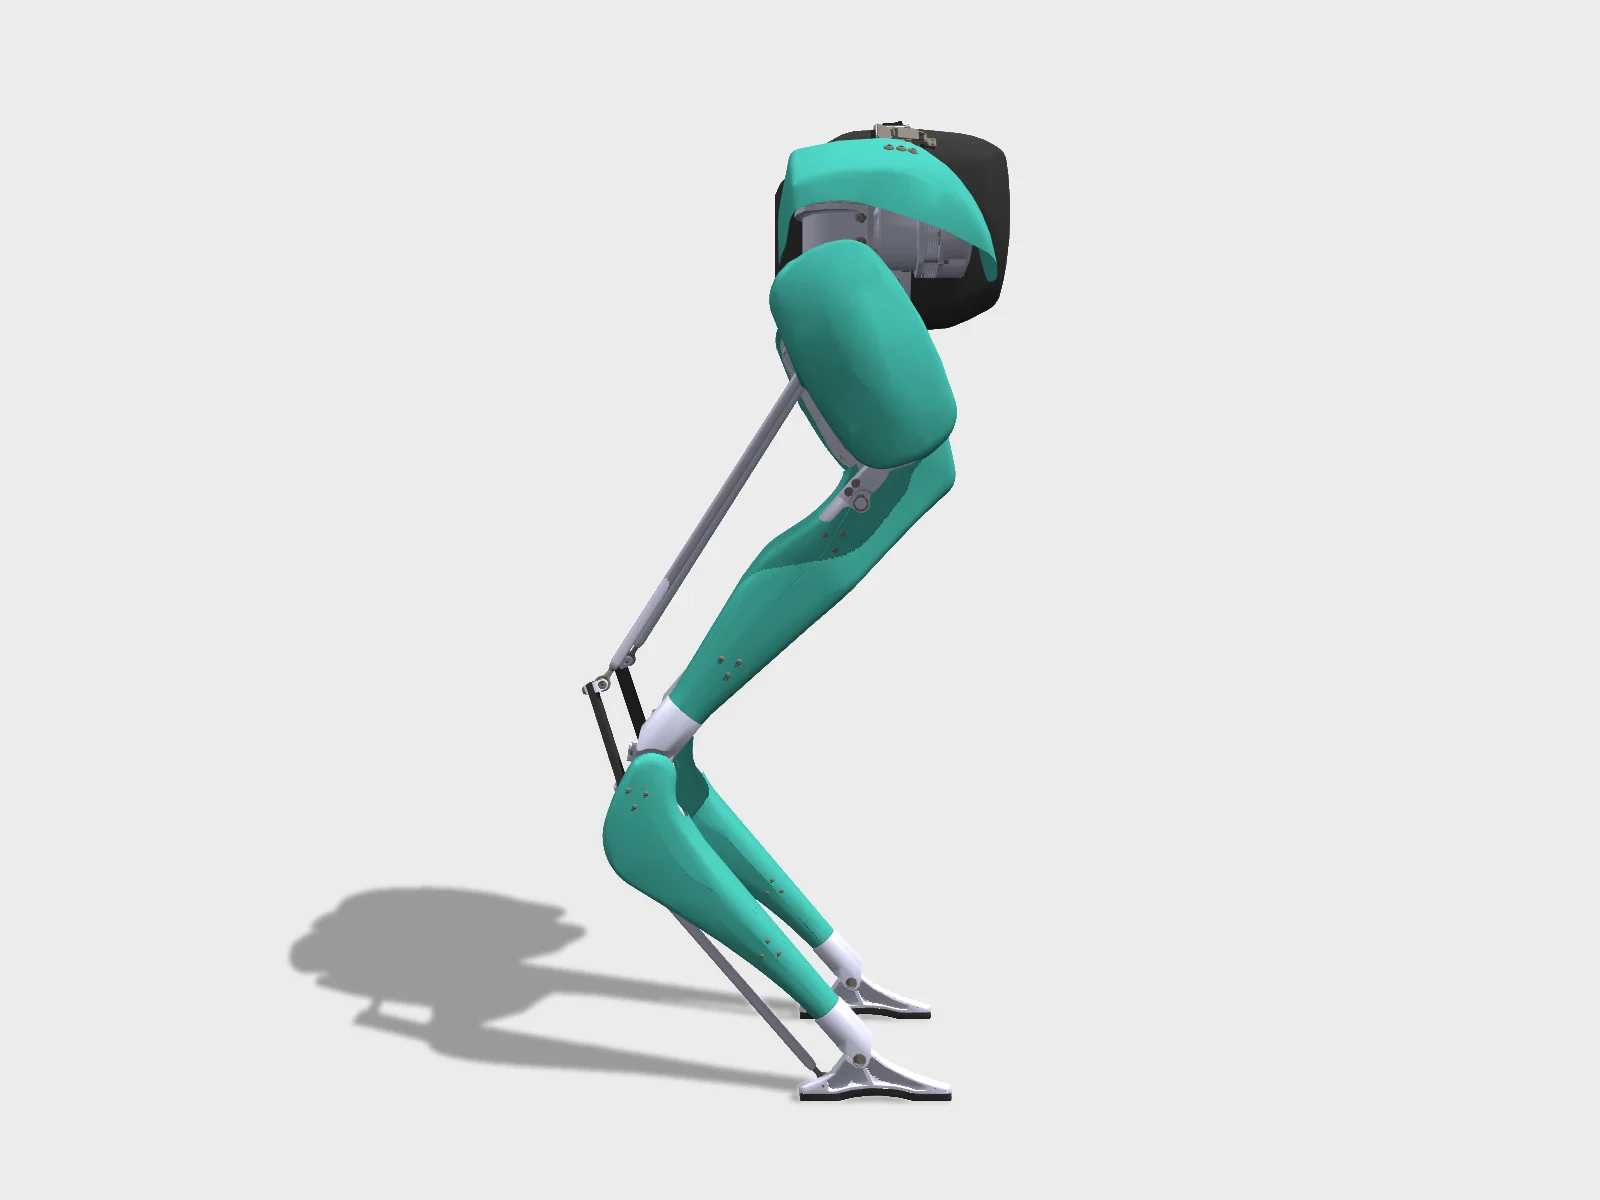
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 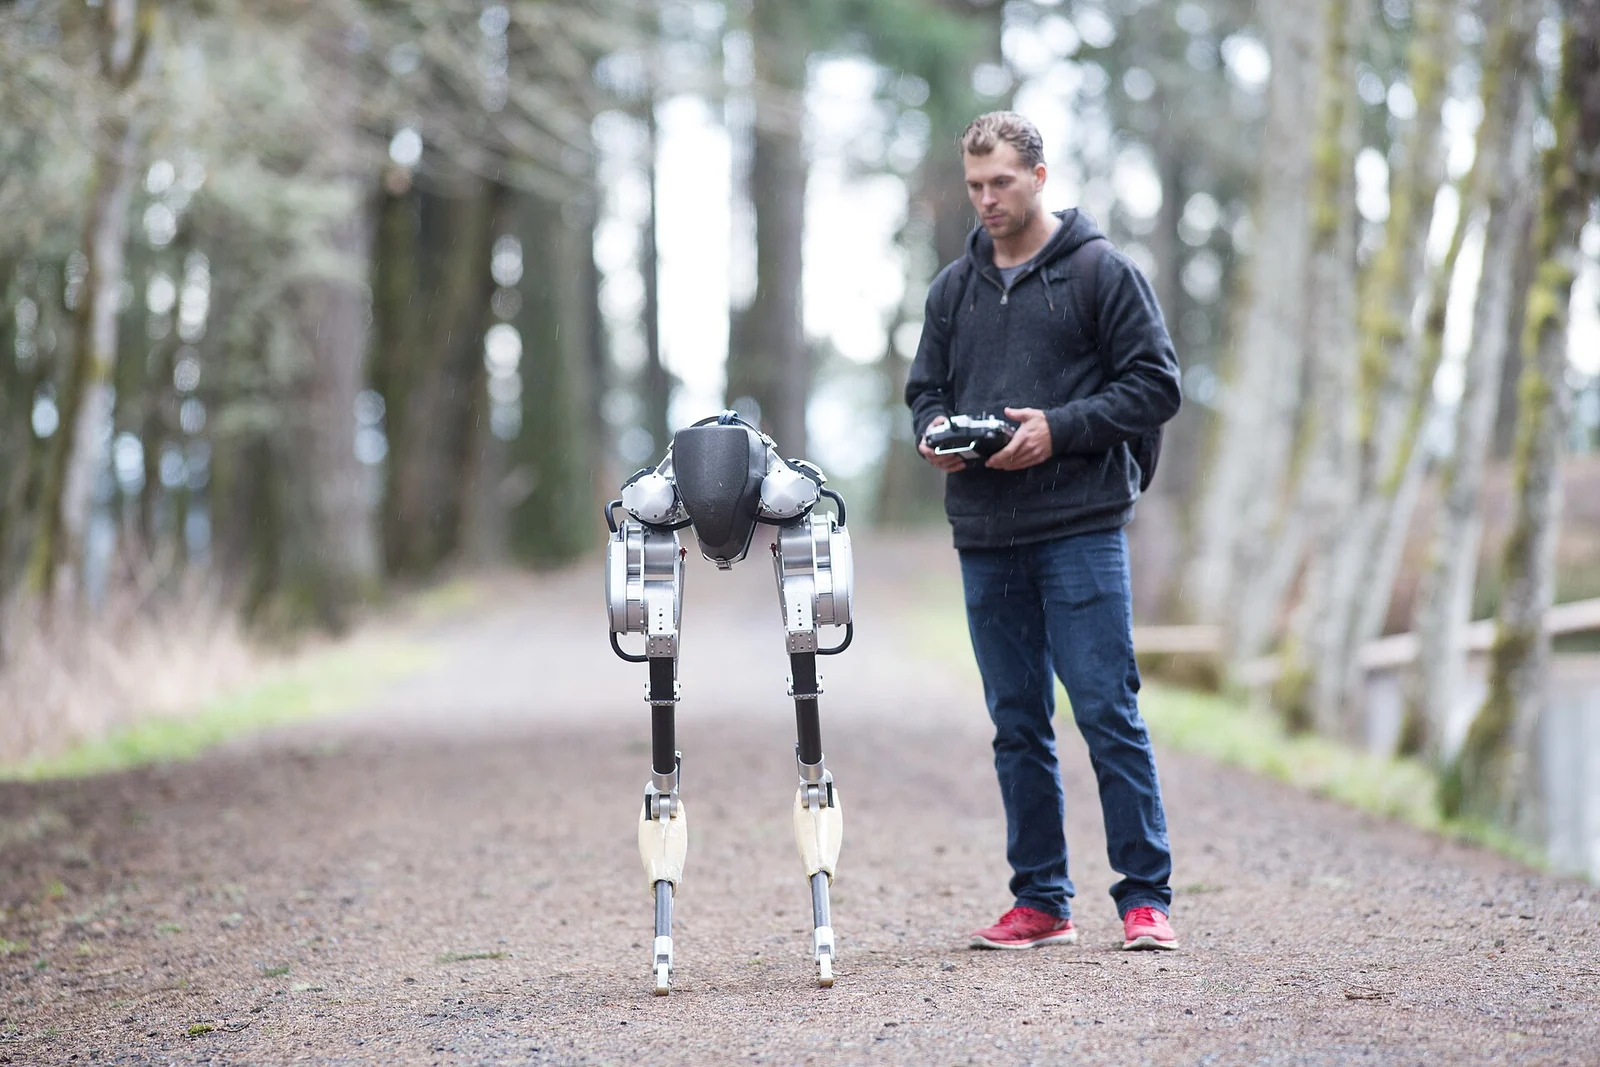
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source 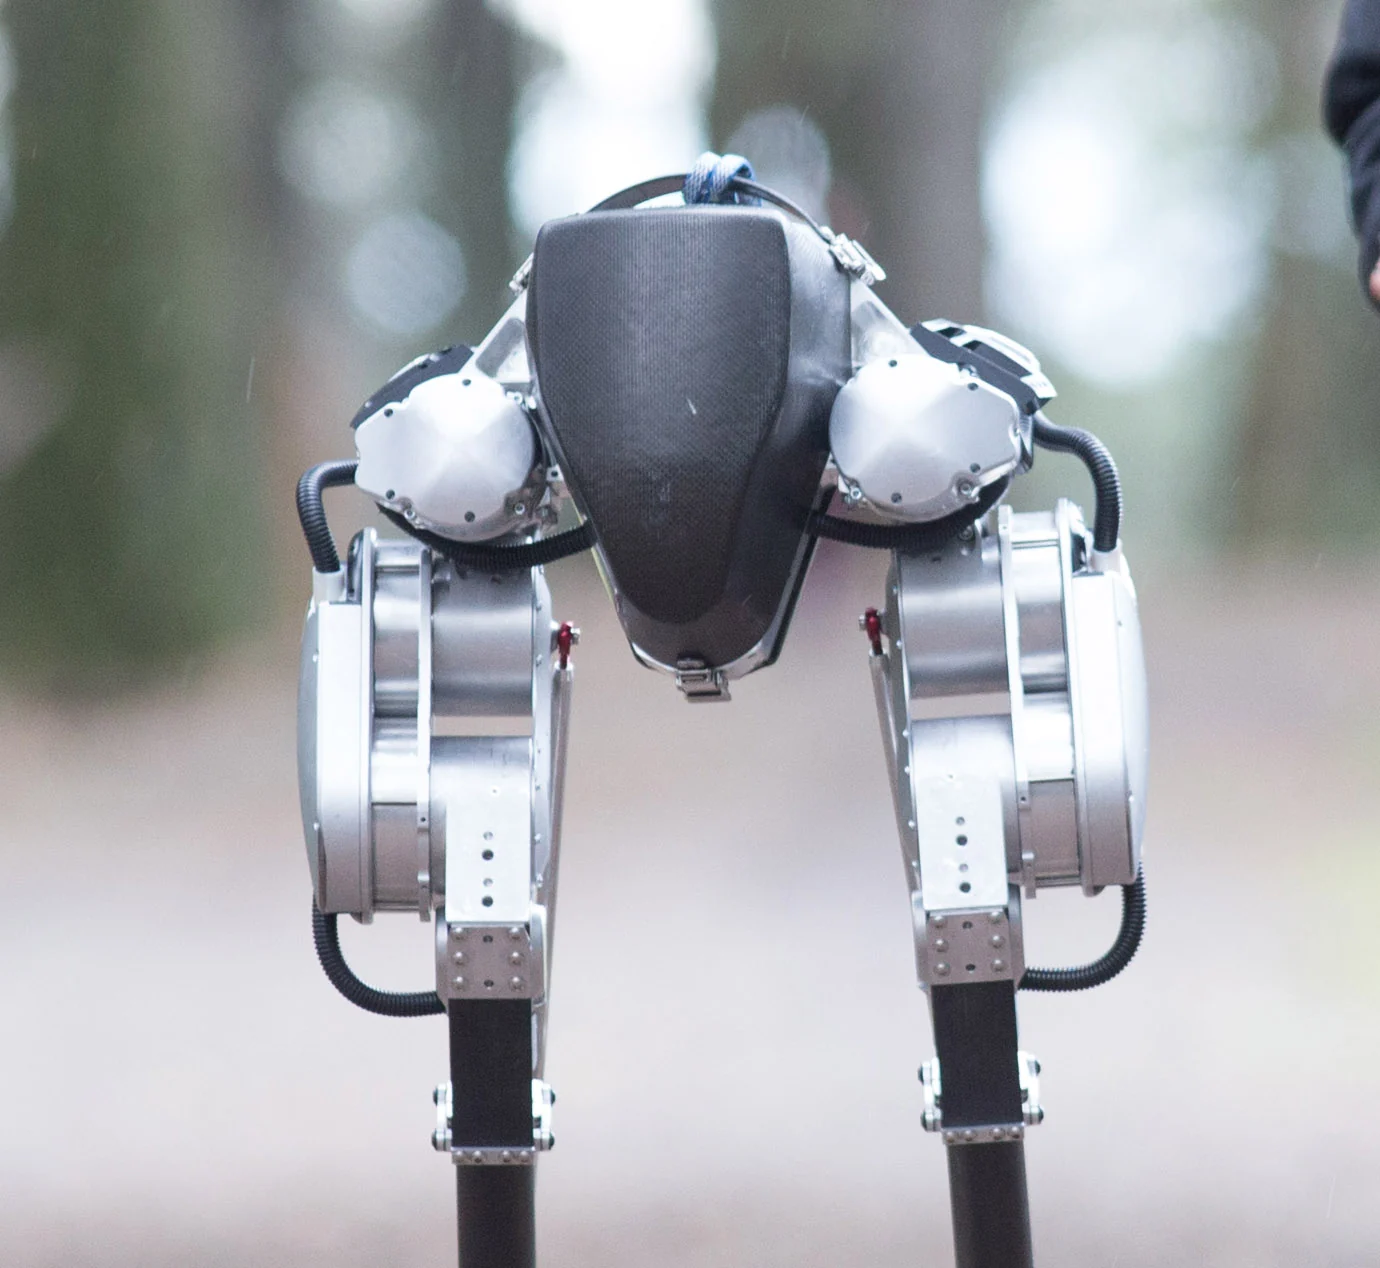
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source Meet CassieAgility · official embed · source Cassie Sets World Record for 100M RunAgility · official embed · source OSU Bipedal Robot First to Run 5KOregon State University · official embed · source


Crew closed
Cassie has no crew here.
Not sold to individuals or labs. A crew page is only useful for a robot people can build or maintain themselves. If Agility Robotics opens the hardware, this page opens with it.